2025–2026 Season

DECODE

Our second season: Sustain Award and a trip to States.

The Robot

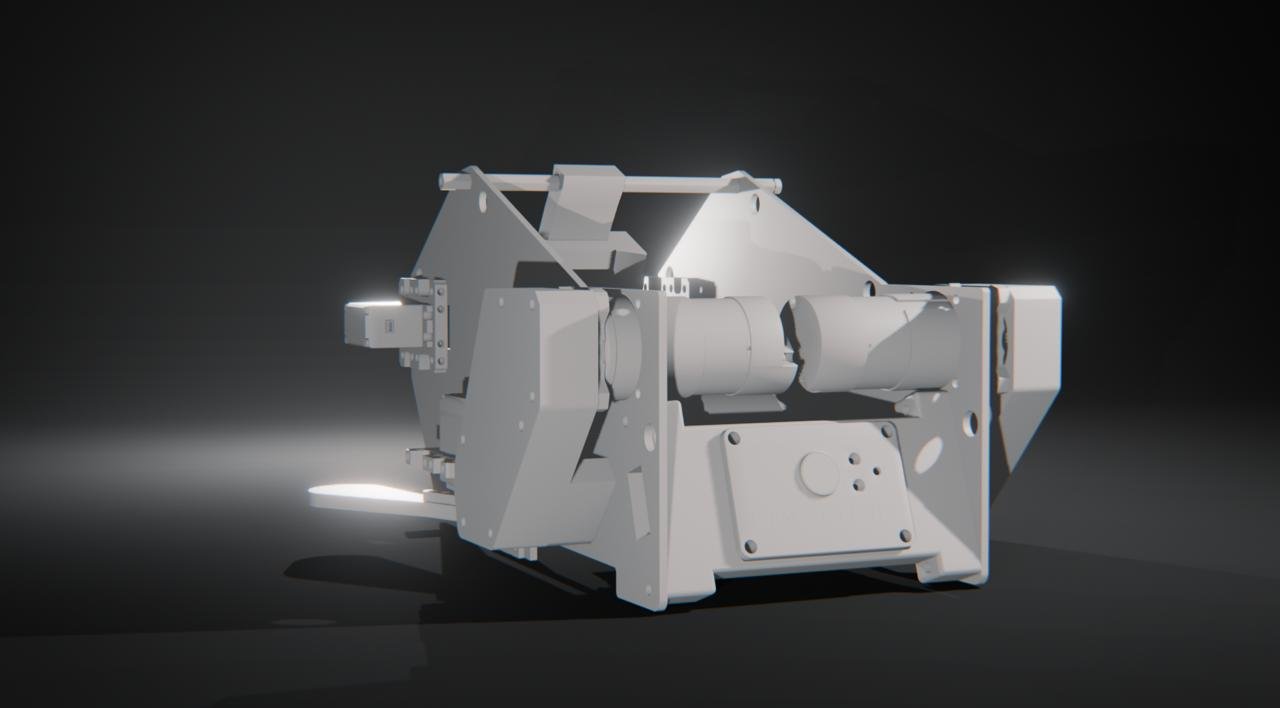
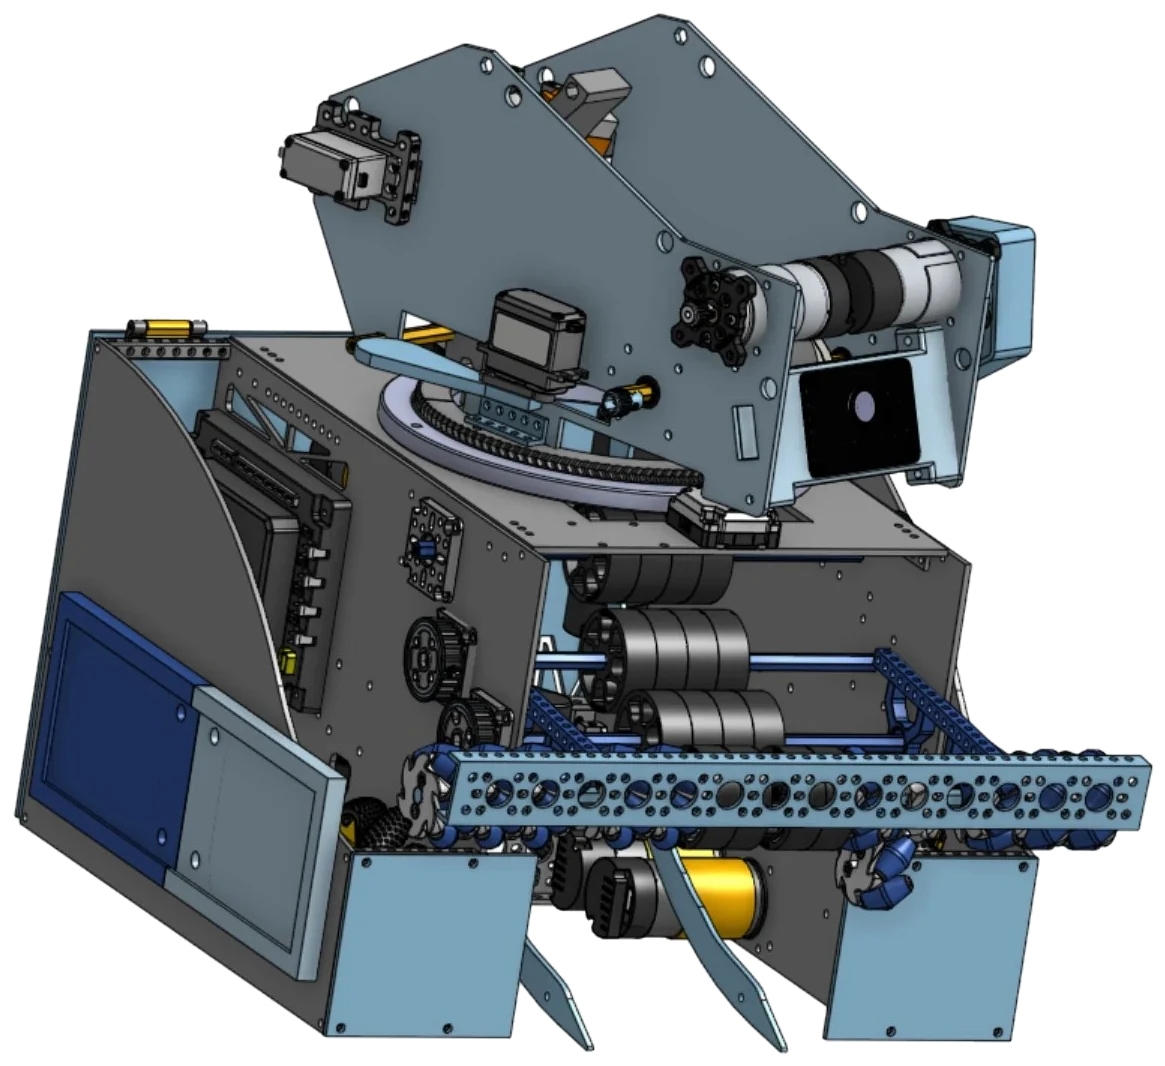
CAD render of Mercury's DECODE robot with its intake, transfer, and turret shooter

Winning alliance, Sustain Award & a trip to States

Early on we considered a sorting indexer so we could score patterns for the ranking point. It would have been more complex, less reliable, and slower, so we built a direct-transfer robot instead: a parallel-plate chassis, a full-width gecko-wheel intake, a 0.34-second transfer, and a flywheel shooter on a 360° turret that tracks the goal with a Limelight.

  • ChassisParallel plate (V3)
  • IntakeCompliant gecko-wheel bar
  • TransferCustom rails, 0.34 s
  • ShooterFlywheel on a lazy-susan turret
  • VisionLimelight, PD tracking
  • Autonomous18-ball close / 9-ball far
0.34 s
Transfer time
18
Ball autonomous
360°
Turret rotation
3
Sets of gecko wheels

Mechanisms & iterations

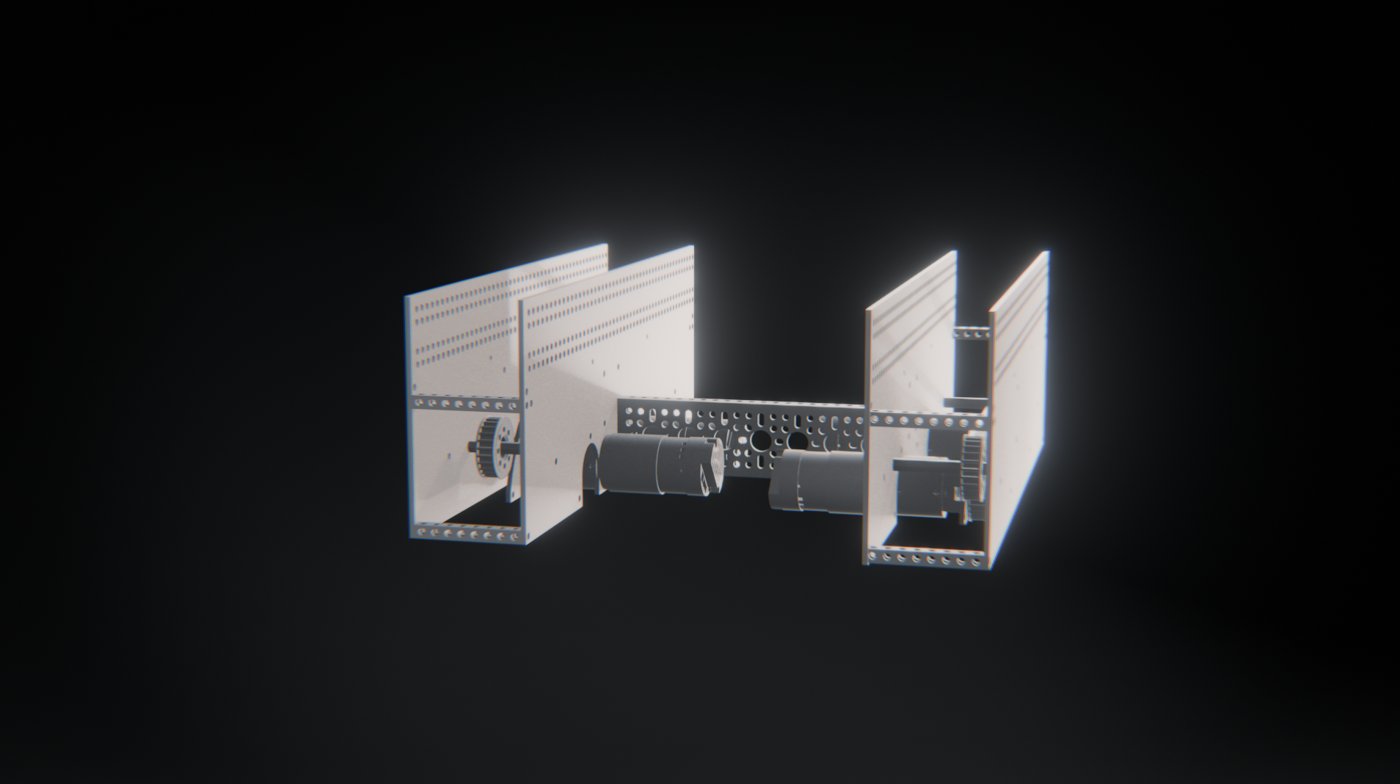
CAD render of the V2 parallel-plate chassis

Chassis

V1's parallel plates gave us maneuverability and defense but had no mounting holes, and the U-channels we added made it heavy. V2 added holes and cut weight, but its wood plates could break. V3 keeps components easy to remove for maintenance.
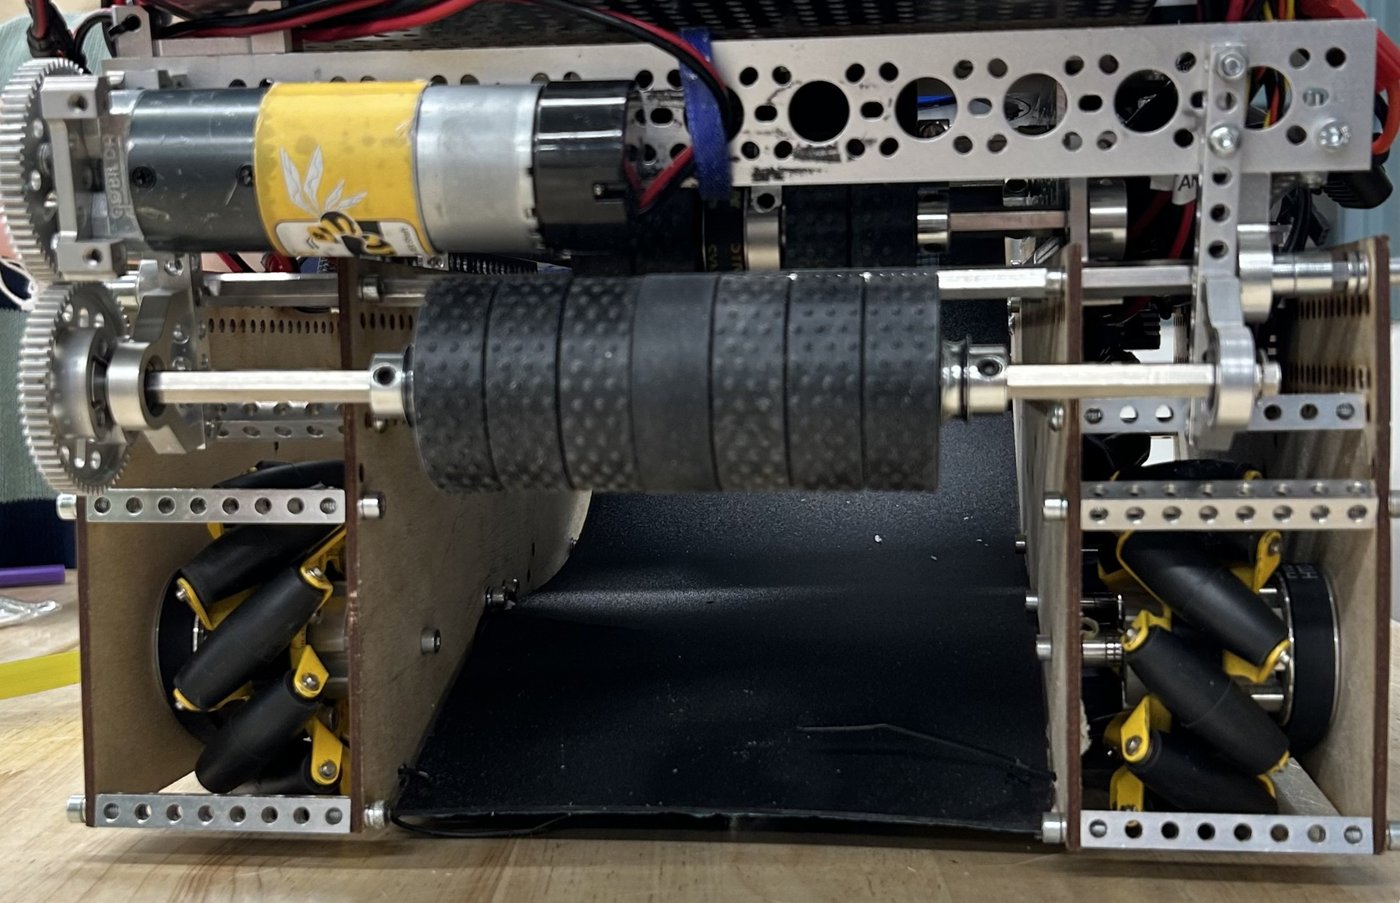
Mercury's V2 intake with a horizontal bar of gecko wheels

Intake

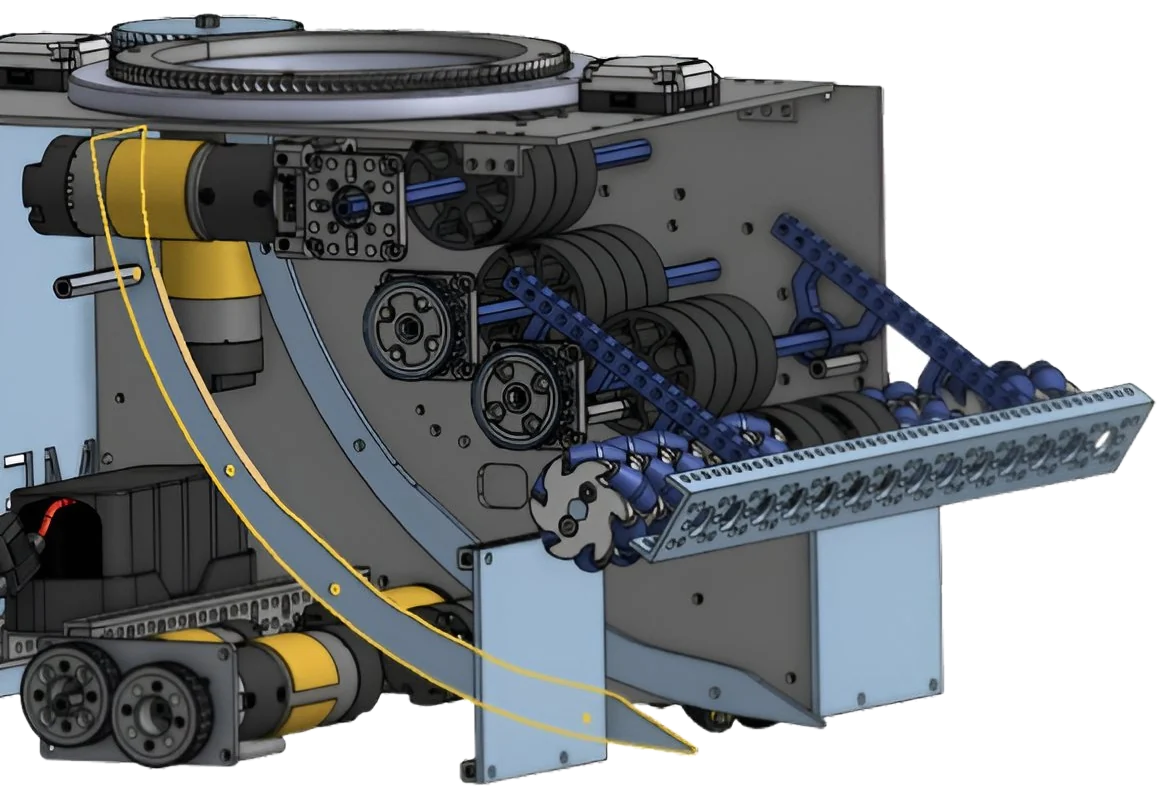
Two gecko wheels on two motors needed too much precision. V2 used one motor and a horizontal bar of gecko wheels. V3 is compliant, runs the full 14 in width of the chassis, and uses vectored wheels to push balls to the center.

CAD render of the V3 transfer with custom rails

Transfer

V1 took 1.5 s to bring a ball to the shooter. V2 moved several balls at once in 0.9 s. V3 uses custom CADed rails on a constant incline to shrink the footprint and gets a ball to the shooter in 0.34 s.

CAD render of shooter version 4

Shooter

Four versions: a bulky fixed hood, a sturdier but large build, a smaller modular one that was unstable, and V4 with stable side plates, the motors in front, and a front-mounted Limelight.

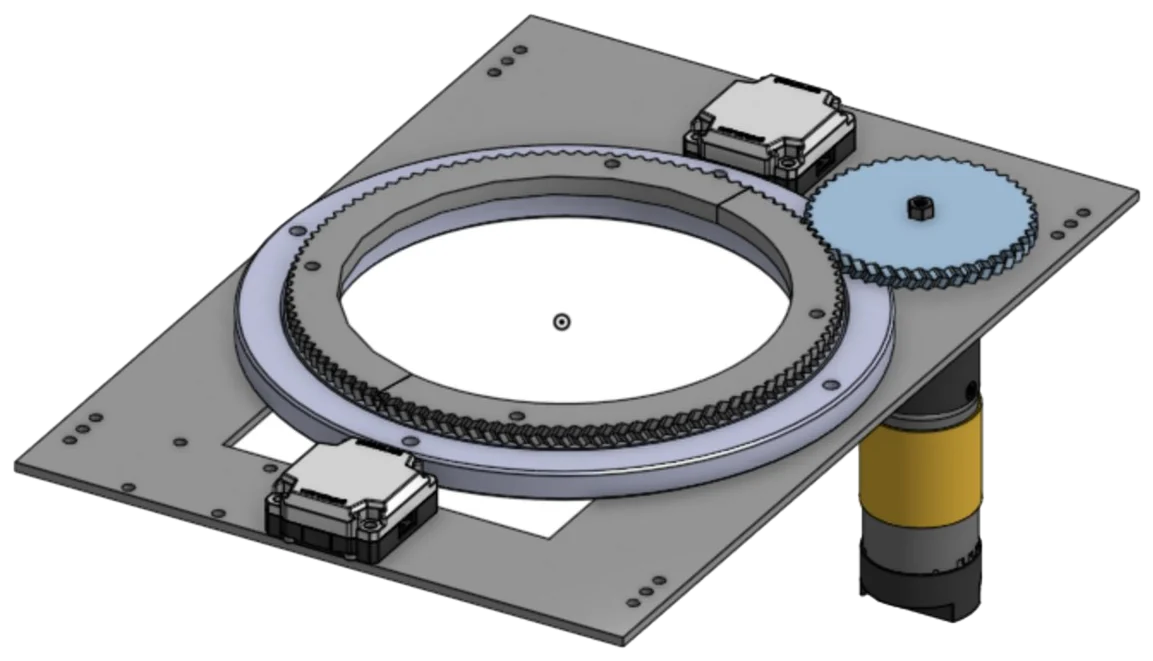
CAD of the turret top plate, lazy susan, and herringbone gear

Turret

A pulley drive lost tension and took up space, so we switched to a 1:3 herringbone gear mounted to a lazy susan in the top plate. Spring-loaded key retractors manage the wires through the full 360°.

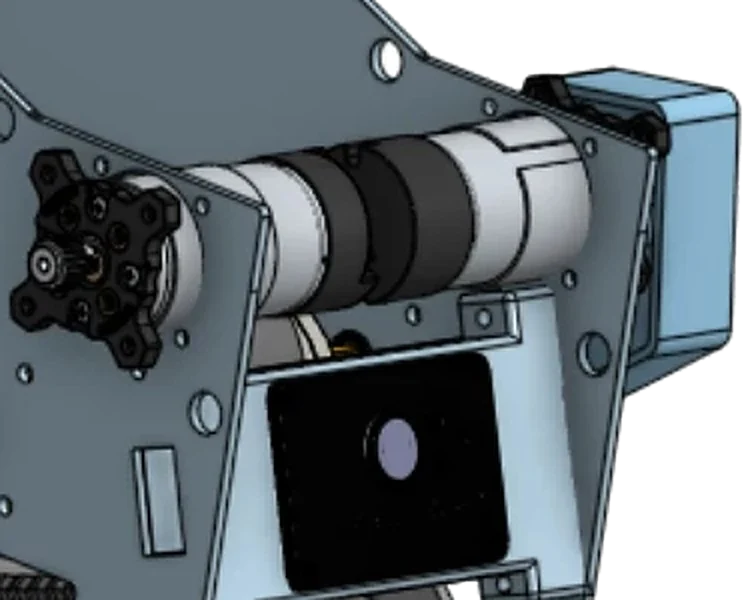
CAD render of the Limelight mounted on the front of the shooter

Limelight

After trial and error, we mounted the Limelight directly in front of the shooter. It gives more accurate shots and also helps support the shooter's structure.

Software & autonomous

Turret tracking

Search, track, lock, hold

A PD controller turns the turret toward the target and holds within ±1°. If the Limelight drops a frame, an 8-frame buffer keeps it from snapping into search mode, and it sweeps back toward where it last saw the target, cutting re-acquisition time by 50%. Encoder-based limits stop the turret before it can damage the gearbox.

Shooter

Distance-based RPM

A lookup table maps 7 calibrated distances (1.1–3.34 m) to flywheel speeds from 3000 to 3975 RPM, with linear interpolation in between and a PIDF loop holding the speed. Inside 1.3 m, the hood angle changes for short shots.

Autonomous

18-ball close, 9-ball far

We use PedroPathing, and thanks to other teams we ran a newer, unreleased version that made our autonomous much more consistent. The close-side routine shoots the preload, then collects and scores triples three more times for 18 balls. The far side scores 9.

Strategy

Defense with a parallel plate

Our code is organized into subsystems, and we tune our turret, flywheel, and autonomous loops live with telemetry. In matches, the parallel-plate chassis lets us play defense and block the other alliance from scoring.

Events

Massachusetts State Championship

Mar 15, 2026
Alliance
—
Awards
—

We competed at States after qualifying through our Ryken RoboBowl result.

WNEU Qualifier

Jan 24, 2026
Alliance
—
Awards
Sustain Award

Alongside our matches, the team received the Sustain Award at WNEU.

Ryken RoboBowl Qualifier

Dec 14, 2025
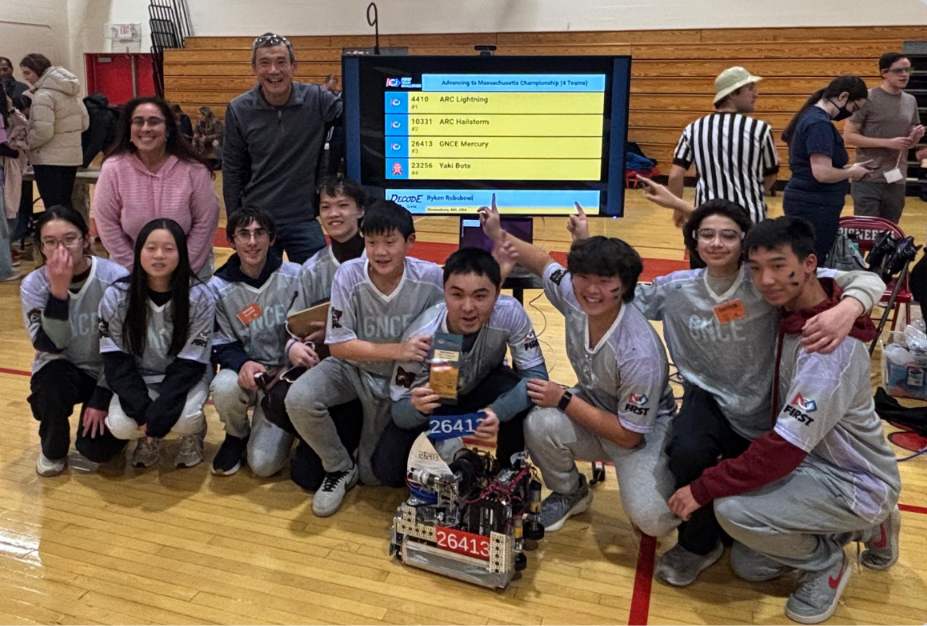
GNCE Mercury team with our robot at the Ryken RoboBowl, advancing to the Massachusetts Championship
Alliance
Winning Alliance · 1st Pick
Awards
Winning Alliance

This win earned us our spot at the Massachusetts State Championship.